Tools & Research · Prototype
Singlepass Studio
A drone reconstruction operator interface with a point-cloud viewer and observability shading.
Python3D reconstructionPoint clouds
Explore repository 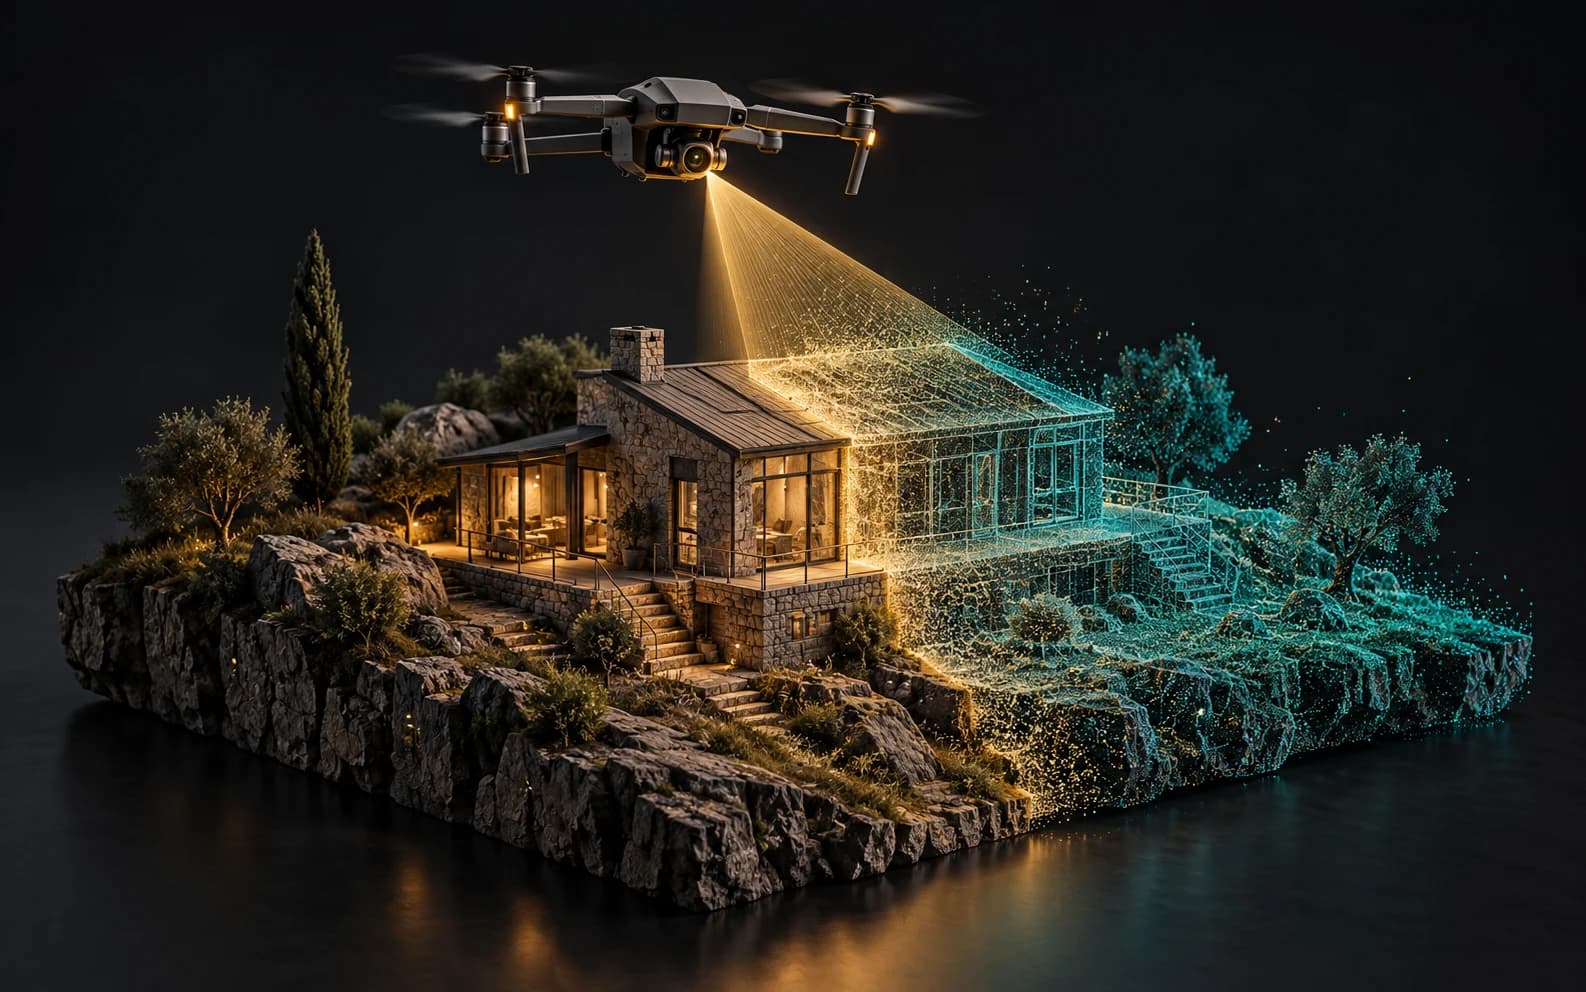
The project
An operator interface wireframe for single-pass drone 3D reconstruction, built around a brass-on-graphite visual system. The associated feasibility harness explores GPU capacity, metric scale, parallax, and scene visibility against synthetic ground truth.
Repository activity ·
Inside the build
- 01Point-cloud inspection and observability shading
- 02Operator interface for a single-pass reconstruction workflow
- 03Associated synthetic-scene feasibility experiments